HL Only: Torque
Torque of a force about an axis is given by .
Include the clockwise or counter-clockwise sense when identifying a torque.
A formal vector treatment of torque is not required.
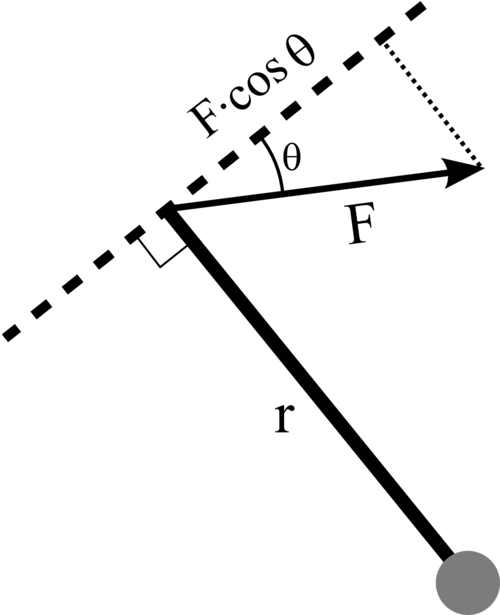
The diagram visualises the quantities used in . It helps connect the applied force, distance from the axis and angle.
HL Only: Uniform angular acceleration equations
Relationship | Equation |
|---|---|
Angular displacement | |
Final angular speed | |
Angular displacement | |
Speed–displacement relationship |
HL Only: Moment of inertia
Moment of inertia depends on the distribution of mass about the axis of rotation.
For a system of point masses, calculate it using .
Each contribution contains , so distance from the rotation axis has a squared effect on the contribution to .
For a specific extended-body mass distribution, the required moment of inertia equation will be provided.
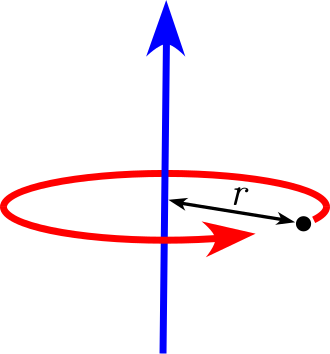
A point mass lies a distance from the rotation axis. This visualises the contribution in .
HL Only: Angular impulse
A resultant torque acting for a time interval produces an angular impulse.
The change in angular momentum is .
Relate changes in and to the resulting when a torque acts.
HL Only: Modelling and examination scope
No centre of mass calculation is required.
For linear motion, an extended body’s mass may be treated as concentrated at its centre of mass.
Simultaneous rotational and translational motion is restricted to rolling without slipping.
A specific moment of inertia equation will be provided when necessary.
Questions include changes in for extended bodies and coupled pairs of bodies.
Use angular speed instead of a formal vector treatment of angular velocity.
HL Only: Rotational equilibrium
A body is in rotational equilibrium when the resultant torque is zero.
Clockwise and counter-clockwise torques must combine to give .
An unbalanced torque on an extended rigid body causes angular acceleration.
HL Only: Describing rotational motion
Rotation is described using angular displacement , angular velocity and angular acceleration .
For this course, angular speed is used rather than a formal vector treatment of angular velocity.
The term angular velocity is still used, but formal vector treatment is not required.
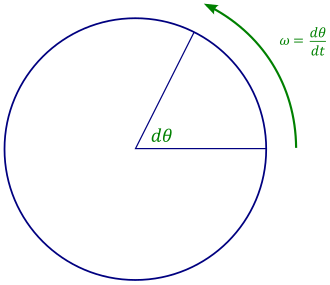
The diagram represents rotational motion and angular velocity . Use it to visualise angular motion without requiring formal vector analysis.
HL Only: Newton’s second law for rotation
Newton’s second law for rotation is , where is the average torque.
The equation links the applied torque with the body’s moment of inertia and angular acceleration .
Use it for the rotational dynamics of an extended rigid body.
HL Only: Angular momentum and conservation
A rotating extended body has angular momentum .
Angular momentum remains constant unless the body is acted upon by a resultant torque.
If the resultant torque is zero, remains constant.
Situations may involve changing in extended bodies and coupled pairs of bodies.
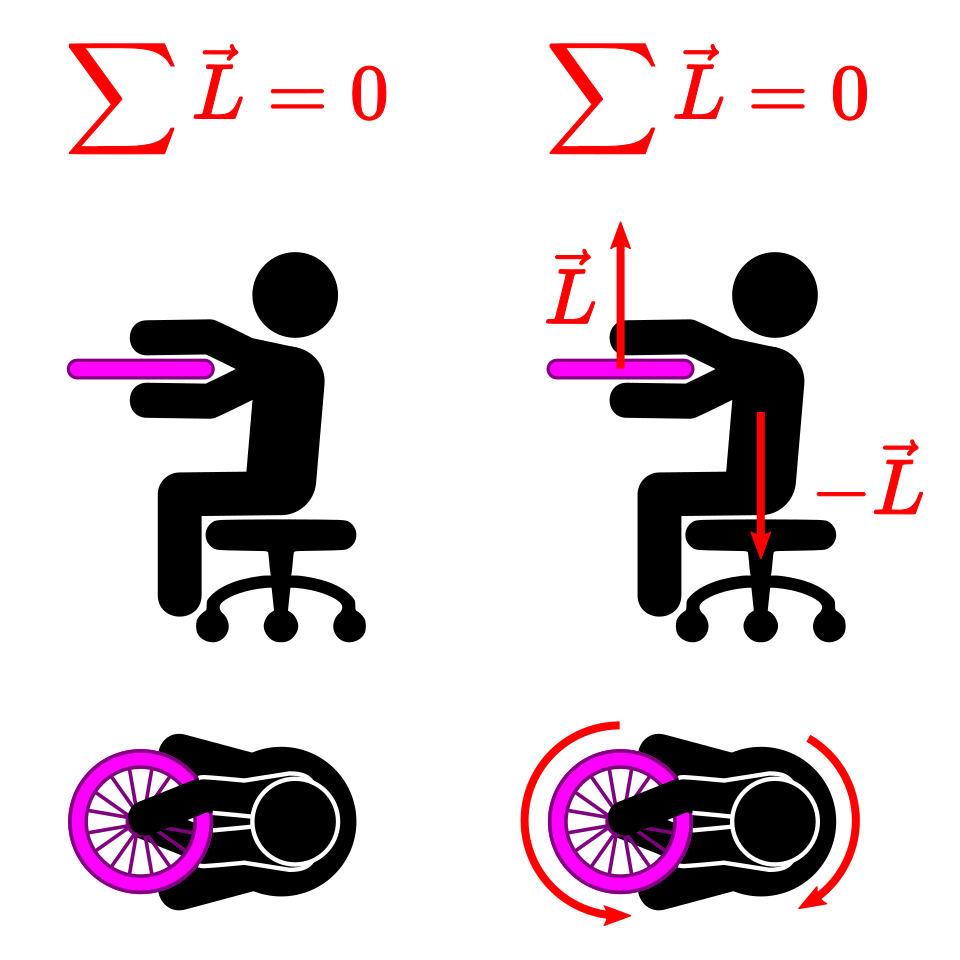
The wheel demonstration illustrates conservation of angular momentum. When no resultant external torque acts, use as the conserved rotational quantity.
HL Only: Rotational kinetic energy
The kinetic energy of rotational motion is .
It can also be written as .
Choose the form that matches the quantities supplied in the problem.
HL Only: Checklist: can you do this?
Can you calculate torque using and include its clockwise or counter-clockwise sense?
Can you determine whether a rigid body is in rotational equilibrium?
Can you use the four uniform angular acceleration equations correctly?
Can you calculate moment of inertia for point masses using ?
Can you apply to rotational dynamics?
Can you use and conservation of angular momentum?
Can you calculate angular impulse using ?
Can you calculate rotational kinetic energy and recognise the rolling without slipping restriction?